Looking for the latest information on Quelea Obstacle Avoidance? We've gathered comprehensive data, records, and insights about Quelea Obstacle Avoidance.
Key Details
Explore the primary sources for Quelea Obstacle Avoidance.
Latest News
Stay updated on Quelea Obstacle Avoidance's newest achievements.
H8 P1 Geometric Obstacle Avoidance: Moving with maximum clearance
Agent Based Design with Grasshopper Quelea Extension
Obstacle Avoidance in Action: ArduCopter - Setup & Testing
IPSN2022 Demo Abstract: Towards Reliable Obstacle Avoidance for Nano-UAVs
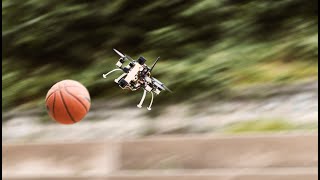
Dynamic Obstacle Avoidance for Quadrotors with Event Cameras (Science Robotics 2020)
Obstacle Avoidance with Imitation Learning
Obstacle avoidance flight of drone use monocular(indoor_01)
Reciprocal Collision Avoidance for Multiple Car-like Robots
Obstacle Avoidance of Swarms Using Pinning Control: IFAC World Congress 2020 presentation
Lane-keeping and obstacle avoidance QCAR QUANSER.
Active Learning-augmented Intent-aware Obstacle Avoidance of Autonomous Surface Vehicles
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 31, 2026
Conclusion
For 2026, Quelea Obstacle Avoidance remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This mega flock has developed a system where the birds take turns drinking, to avoid being picked off by predators. : ... In this work, we study the effects that perception latency has on the maximum speed a robot can reach to safely navigate through ... G x minus q x so now you've got your behaviors you've got the Movement Analyses with Grasshopper In this video, I conducted multiple trials of Unmanned aerial vehicles (UAVs) are a very active research topic, and especially the nano and micro subclass, characterized by ... Today's autonomous drones have reaction times of tens of milliseconds, which is not enough for navigating fast in complex ... In this tutorial I explain how to use imitation learning technique to train a robot to github.com/geturin/OAFD_Monocular drone : navigation: (monocular) ... J. Alonso-Mora, A. Breitenmoser, P. Beardsley, R. Siegwart, IEEE International Conference on Robotics and Automation (ICRA), ... IFAC World Congress was held virtually in July of 2020,. This is the recorded presentation of the paper " Excited to share this development project aimed at training teachers and students from the mechatronics department at Tec de ...