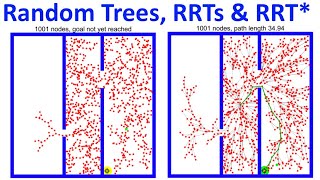
Looking for the latest information on Rrt X With Batch Informed Tree? We've compiled comprehensive data, records, and insights about Rrt X With Batch Informed Tree.
Important Facts
Explore the key sources for Rrt X With Batch Informed Tree.
Developments
Stay updated on Rrt X With Batch Informed Tree's newest achievements.
Comparison of RRTX, RRT# and RRT* when a shortcut is discovered in a static environment
Bit*(Batch Informed Trees) with dynamic Obstacles(Anytime)
AM-RRT*: Informed Sampling-based Planning with Assisting Metric (ICRA 2021)
[PythonRobotics] RRT* with reeds-sheep path
BIT*(Batch informed Trees) with Dynamic Obstacles(Anytime)
[PythonRobotics] Rapidly Randomized Tree (RRT) path planning sample
Robot Path Planning: RRT* v/s BIT*
[PythonRobotics] Informed RRT* path planning
Advanced BIT* (ABIT*) - ICRA 2020 @ ORI
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 31, 2026
Conclusion
For 2026, Rrt X With Batch Informed Tree remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video shows an improvement to the popular In this video we show a new approach to path planning that combines the benefits of our global Lecture 24 of Intro to Robotics @ University of Houston. using ... Accompanying video for ICRA 2021 paper ( arxiv.org/pdf/2010.14693.pdf) on our RT- Code is here: github.com/AtsushiSakai/PythonRobotics/blob/master/PathPlanning/ The above video shows a comparison between two path planning algorithms: 1. Rapidly exploring Random Code is here: PythonRobotics/informed_rrt_star.py at master · AtsushiSakai/PythonRobotics ... A video for our ICRA 2020 paper, "Advanced BIT* (ABIT*): Sampling-Based Planning with Advanced Graph-Search Techniques" ...