Looking for the latest information on Tp Space Rrt? We've gathered comprehensive data, records, and insights about Tp Space Rrt.
Core Information
Explore the main sources for Tp Space Rrt.
Recent Updates
Stay updated on Tp Space Rrt's newest achievements.
A* and RRT* PathFinding - Alrys
Path Planning with A* and RRT | Autonomous Navigation, Part 4
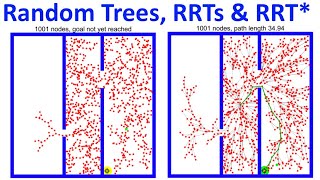
3 Minutes of RRT
Rapidly-exploring Random Tree [RRT] Algorithm Implementation in Python | Robotics
Transition-based RRT for Path Planning in Continuous Cost Spaces
RRT* in a 3D Environment
RRT* algorithm on the PR2 - planning with both arms (12 DOF)
PATH PLANNING: RRT algorithm implementation for AMR
Our implementation of Real-time RRT* with multi-query support
Transition-Based RRT for Path Planning in Continuous Cost Spaces
Physically Simulated Car - Stable Sparse RRT (SST)
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 31, 2026
Conclusion
For 2026, Tp Space Rrt remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Sample from PRRT github.com/j3sq/prrt. Lecture 24 of Intro to Robotics @ University of Houston. using ... See the other videos in this series: youtube.com/playlist?list=PLn8PRpmsu08rLRGrnF-S6TyGrmcA2X7kg This video ... Rapidly-exploring random tree is a graph constructing algorithm for uniform sampling in state- Algorithm implemented in Unity3D. Based upon the whitepaper: homepages.laas.fr/jcortes/Papers/jaillet_aaaiWS08.pdf. An example run for Stable Sparse-